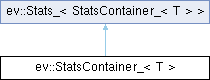
This class keeps the ingredients of the statistics of Stats_ up to date without storing the events.
More...
#include <stats_container.hpp>
|
|
using | value_type = Event_<T> |
|
using | ResultType |
|
| void | push (const Event_< T > &e) |
| | Account for an event.
|
| std::size_t | size () const |
| | Number of events accounted for.
|
| bool | empty () const |
| | Check whether no event was accounted for.
|
| TimeType | firstTimestamp () const |
| TimeType | lastTimestamp () const |
| cv::Point2d | sum () const |
| double | sumT () const |
| double | sumP () const |
| cv::Vec3d | squares () const |
| cv::Rect | bounds () const |
| std::size_t | activeCount () const |
| std::size_t | peakCount () const |
| double | sumCLogC () const |
|
void | clear () |
| | Forget every event. The per-pixel count keeps its extent, so accounting for a similar stream again does not grow it.
|
| ResultType | duration () const |
| | Time difference between the last and the first event.
|
| ResultType | rate () const |
| | Compute event rate as the ratio between the number of events and the time difference between the last and the first event.
|
| ResultType | density (const cv::Size size) const |
| | Compute event density as the ratio between the number of events and the number of pixels.
|
| std::size_t | activePixels () const |
| | Count the pixels with at least one event.
|
| ResultType | fillRatio (const cv::Size size) const |
| | Compute fill ratio as the fraction of pixels with at least one event.
|
| ResultType | polarityRatio (const PolarityType p) const |
| | Compute polarity ratio as the fraction of events with the given polarity.
|
| Event_< ResultType > | mean () const |
| | Compute the mean of the events.
|
| cv::Point_< ResultType > | meanPoint () const |
| | Compute the mean x,y point of the events.
|
| cv::Matx< ResultType, 2, 2 > | covariance () const |
| | Compute the covariance of the x,y coordinates of the events around meanPoint().
|
| cv::Rect | boundingBox () const |
| | Compute the smallest rectangle of pixels containing the events.
|
| ResultType | meanTime () const |
| | Compute the mean time of the events.
|
| ResultType | midTime () const |
| | Calculate the midpoint time between the oldest and the newest event.
|
| std::size_t | peak () const |
| | Find the largest number of events on a single pixel.
|
| ResultType | entropy () const |
| | Compute the Shannon entropy of the spatial distribution of the events.
|
template<typename T>
class ev::StatsContainer_< T >
This class keeps the ingredients of the statistics of Stats_ up to date without storing the events.
Analogously to OpenCV library, the following aliases are defined for convenience:
This class keeps the ingredients of the statistics of Stats_ up to date without storing the events.
Definition stats_container.hpp:56
StatsContainer_< long > StatsContainerl
Definition stats_container.hpp:184
StatsContainer_< double > StatsContainerd
Definition stats_container.hpp:186
StatsContaineri StatsContainer
Definition stats_container.hpp:187
StatsContainer_< float > StatsContainerf
Definition stats_container.hpp:185
StatsContainer_< int > StatsContaineri
Definition stats_container.hpp:183
◆ activeCount()
Number of pixels with events
◆ bounds()
Smallest rectangle of pixels holding the events
◆ empty()
Check whether no event was accounted for.
- Returns
- True if empty
◆ firstTimestamp()
Timestamp of the first event
◆ lastTimestamp()
Timestamp of the last event
◆ peakCount()
Largest number of events on a pixel
◆ push()
Account for an event.
- Parameters
-
◆ size()
Number of events accounted for.
- Returns
- Event count
◆ squares()
◆ sum()
◆ sumCLogC()
Sum of c*log2(c) over the pixel counts c
◆ sumP()
◆ sumT()
The documentation for this class was generated from the following file:
 1.17.0