|
| | SpaceTime_ (const cv::Size canvas, const cv::Size sensor=cv::Size()) |
| | Construct the canvas.
|
| void | setView (const double yaw, const double pitch) |
| | Set the view angles.
|
| void | setDepth (const double depth) |
| | Set the depth of the box, that is, how long the time axis is drawn.
|
| void | showAxes (const bool state, const double length=DEFAULT_AXES_LENGTH) |
| | Draw the x, y and t axes from the sensor origin, labelled at their ends.
|
| void | fadeWithDepth (const bool state, const double strength=DEFAULT_FADE) |
| | Fade the events towards the background as they recede, so the depth shows.
|
| void | setAxesValue (const typename TypeHelper< T >::Type &value) |
| | Set the value the axes are drawn with.
|
| void | setAxesColor (const cv::viz::Color &color) |
| | Set the colour the axes are drawn with. For more information, please refer here.
|
| double | yaw () const |
| | Yaw of the view.
|
| double | pitch () const |
| | Pitch of the view.
|
| cv::Size | sensorSize () const |
| | Sensor size.
|
| cv::Point2d | project (const Event_< E > &e, const double age) const |
| | Project an event onto the canvas with the current view.
|
| cv::Mat & | render () |
| | Render the space-time view.
|
|
| EventImage_ (Args &&...args) |
|
cv::Mat & | render () |
| std::size_t | count () const |
| | Number of events integrated in the representation.
|
| TimeType | firstTimestamp () const |
| | Timestamp of the oldest event integrated in the representation.
|
| TimeType | lastTimestamp () const |
| | Timestamp of the newest event integrated in the representation.
|
| void | clear () |
| | Remove all events from the representation.
|
| bool | insert (const Event_< int > &e) |
| | Insert one event in the representation.
|
| void | setTimeOffset (const Event_< int > &e) |
| | Set time offset.
|
| void | setValue (const bool polarity, const Type &value) |
| | Set values for ON and OFF pixels.
|
| void | setValues (const Type &positive, const Type &negative, const Type &reset) |
| | Set values for ON, OFF, and non-activated pixels.
|
| void | setColor (const bool polarity, const cv::viz::Color &color) |
| | Set colors for ON and OFF pixels. For more information, please refer here.
|
| void | setColors (const cv::viz::Color &positive, const cv::viz::Color &negative, const cv::viz::Color &reset) |
| | Set colors for ON, OFF, and non-activated pixels. For more information, please refer here.
|
| void | setColormap (const cv::ColormapTypes cm) |
| | Set colormap for the representation.
|
| ResultType | duration () const |
| | Time difference between the last and the first event.
|
| ResultType | rate () const |
| | Compute event rate as the ratio between the number of events and the time difference between the last and the first event.
|
| ResultType | density (const cv::Size size) const |
| | Compute event density as the ratio between the number of events and the number of pixels.
|
| std::size_t | activePixels () const |
| | Count the pixels with at least one event.
|
| ResultType | fillRatio (const cv::Size size) const |
| | Compute fill ratio as the fraction of pixels with at least one event.
|
| ResultType | polarityRatio (const PolarityType p) const |
| | Compute polarity ratio as the fraction of events with the given polarity.
|
| Event_< ResultType > | mean () const |
| | Compute the mean of the events.
|
| cv::Point_< ResultType > | meanPoint () const |
| | Compute the mean x,y point of the events.
|
| cv::Matx< ResultType, 2, 2 > | covariance () const |
| | Compute the covariance of the x,y coordinates of the events around meanPoint().
|
| cv::Rect | boundingBox () const |
| | Compute the smallest rectangle of pixels containing the events.
|
| ResultType | meanTime () const |
| | Compute the mean time of the events.
|
| ResultType | midTime () const |
| | Calculate the midpoint time between the oldest and the newest event.
|
| std::size_t | peak () const |
| | Find the largest number of events on a single pixel.
|
| ResultType | entropy () const |
| | Compute the Shannon entropy of the spatial distribution of the events.
|
template<typename T, const RepresentationOptions Options = RepresentationOptions::NONE, typename E = int>
class ev::SpaceTime_< T, Options, E >
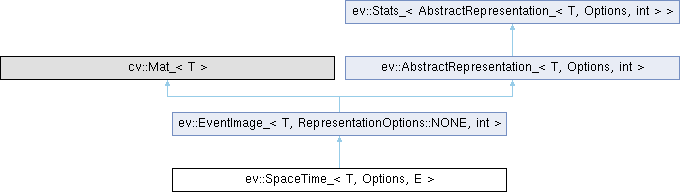
This class extends ev::EventImage_<T> to draw the events as a cloud in the x-y-t volume seen in perspective.
A background given to clear() is an image in sensor coordinates. It is drawn in perspective on the plane of the oldest events, behind the cloud, and follows the view.
Analogously to OpenCV library, the following aliases are defined for convenience:
SpaceTime_(const cv::Size canvas, const cv::Size sensor=cv::Size())
Construct the canvas.
SpaceTime_< cv::Vec3s > SpaceTime3s
Definition space-time.hpp:192
SpaceTime_< cv::Vec3f > SpaceTime3f
Definition space-time.hpp:198
SpaceTime_< cv::Vec3i > SpaceTime3i
Definition space-time.hpp:196
SpaceTime_< cv::Vec3b > SpaceTime3b
Definition space-time.hpp:190
SpaceTime1 SpaceTime
Definition space-time.hpp:203
SpaceTime_< ushort > SpaceTime1w
Definition space-time.hpp:193
SpaceTime_< short > SpaceTime1s
Definition space-time.hpp:191
SpaceTime_< uchar > SpaceTime1b
Definition space-time.hpp:189
SpaceTime1b SpaceTime1
Definition space-time.hpp:201
SpaceTime_< cv::Vec3d > SpaceTime3d
Definition space-time.hpp:200
SpaceTime_< int > SpaceTime1i
Definition space-time.hpp:195
SpaceTime3b SpaceTime3
Definition space-time.hpp:202
SpaceTime_< cv::Vec3w > SpaceTime3w
Definition space-time.hpp:194
SpaceTime_< double > SpaceTime1d
Definition space-time.hpp:199
SpaceTime_< float > SpaceTime1f
Definition space-time.hpp:197
 1.17.0