 |
OpenEV
Extending OpenCV to event-based vision
|
|
OpenEV
Extending OpenCV to event-based vision
|
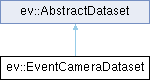
This class extends AbstractDataset to download and open the sequences of the Event-Camera Dataset. More...
#include <event-camera-dataset.hpp>
Public Member Functions | |
| std::string | name () const override |
| Name of the dataset. | |
| std::string | shortname () const override |
| Short name of the dataset, also used as directory name. | |
| std::vector< std::string > | sequences () const override |
| Sequences published by the dataset. | |
| std::string | url (const std::string &sequence) const override |
| Address of the zip file of a sequence. | |
| cv::Size | sensorSize (const std::string &sequence) const override |
| Sensor size of the camera that recorded a sequence. | |
| std::string | cameraName (const std::string &sequence) const override |
| Name of the camera that recorded a sequence. | |
| Public Member Functions inherited from ev::AbstractDataset | |
| AbstractDataset (const AbstractDataset &)=delete | |
| AbstractDataset (AbstractDataset &&) noexcept=default | |
| AbstractDataset & | operator= (const AbstractDataset &)=delete |
| AbstractDataset & | operator= (AbstractDataset &&) noexcept=default |
| void | setDirectory (const std::string &directory) |
| Set the directory where the sequences of this dataset are kept. | |
| std::string | directory () const |
| Directory where the sequences of this dataset are kept. | |
| std::string | path (const std::string &sequence) const |
| Directory of a sequence. | |
| bool | isAvailable (const std::string &sequence) const |
| Check if a sequence has been downloaded. | |
| bool | download (const std::string &sequence, const Progress &progress=nullptr) |
| Download a sequence and extract it in path(). Nothing is done if the sequence is already available. | |
| bool | open (const std::string &sequence, const Progress &progress=nullptr) |
| Open a sequence, downloading it first if it is not available. | |
| void | close () |
| Close the sequence. | |
| bool | isOpen () const |
| Check if a sequence is open. | |
| const std::string & | sequence () const |
| Name of the sequence that is open. | |
| ConcurrentQueue & | events (const std::size_t n=0) |
| Read a given number of events, add them to the queue, and return it, see AbstractReader_::events(). | |
| void | prefetch (const std::size_t n) |
| Keep the queue at a given number of events from a background thread, see AbstractReader_::prefetch(). | |
| std::size_t | prefetchCapacity () const |
| Number of events prefetch() keeps in the queue, see AbstractReader_::prefetchCapacity(). | |
| void | setRoi (const cv::Rect &roi) |
| Deliver only the events inside a region of interest, as the cameras of the devices module do. The events keep their coordinates. | |
| cv::Rect | getRoi () const |
| Get the region of interest. | |
| void | reset () |
| Go back to the beginning of the sequence, see AbstractReader_::reset(). | |
| const FrameFileVector & | frames () const |
| Frames of the sequence, empty if it has none. | |
| const ImuVector & | imu () const |
| Inertial measurements of the sequence, empty if it has none. | |
| const std::string & | error () const |
| Reason why the last download() failed. | |
Static Public Attributes | |
| static constexpr int | WIDTH = 240 |
| static constexpr int | HEIGHT = 180 |
| static constexpr double | SECONDS_TO_MICROSECONDS = 1e6 |
| static constexpr std::array< const char *, 27 > | SEQUENCES |
| Sequences published by the dataset. | |
Additional Inherited Members | |
| Public Types inherited from ev::AbstractDataset | |
| using | Progress = std::function<void(double, double)> |
| Function called while a sequence is being downloaded. | |
| Static Public Member Functions inherited from ev::AbstractDataset | |
| static std::string | cacheDirectory () |
| Directory where downloaded datasets are kept by default. | |
This class extends AbstractDataset to download and open the sequences of the Event-Camera Dataset.
|
nodiscardoverridevirtual |
Name of the camera that recorded a sequence.
| sequence | Sequence name |
Implements ev::AbstractDataset.
|
nodiscardoverridevirtual |
Name of the dataset.
Implements ev::AbstractDataset.
|
nodiscardoverridevirtual |
Sensor size of the camera that recorded a sequence.
| sequence | Sequence name |
Implements ev::AbstractDataset.
|
nodiscardoverridevirtual |
Sequences published by the dataset.
Implements ev::AbstractDataset.
|
nodiscardoverridevirtual |
Short name of the dataset, also used as directory name.
Implements ev::AbstractDataset.
|
nodiscardoverridevirtual |
Address of the zip file of a sequence.
| sequence | Sequence name |
Implements ev::AbstractDataset.
|
staticconstexpr |
Sensor height in pixels
|
staticconstexpr |
Sequences published by the dataset.
|
staticconstexpr |
Sensor width in pixels
 1.17.0