 |
OpenEV
Extending OpenCV to event-based vision
|
|
OpenEV
Extending OpenCV to event-based vision
|
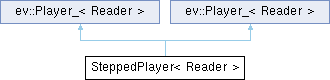
Public Member Functions | |
| SteppedPlayer (Reader &reader) | |
| void | advance (const ev::TimeType time, ev::Queue &events) |
| void | advance (const ev::TimeType time, ev::Queue &events, ev::StampedMatQueue &frames) |
| void | advance (const ev::TimeType time, ev::Queue &events, ev::StampedMatQueue &frames, ev::ImuQueue &imus) |
| Public Member Functions inherited from ev::Player_< Reader > | |
| Player_ (Reader &reader) | |
| Construct the player. The playback starts with the first call to next(). | |
| void | setSpeed (const double speed) |
| Set the playback speed. | |
| double | speed () const |
| Get the playback speed. | |
| void | pause (const bool paused) |
| Hold the playhead, so next() delivers nothing. | |
| bool | isPaused () const |
| Check if the playback is paused. | |
| void | setLoop (const bool loop) |
| Choose what happens when the reader runs out of events. | |
| void | restart () |
| Start again from the beginning. | |
| std::size_t | loops () const |
| Number of times the playback has started again, either by restart() or by reaching the end. | |
| TimeType | playhead () const |
| Current position of the playback, which starts at the timestamp of the first event. | |
| bool | isFinished () const |
| Check if the reader ran out of events with setLoop(false). | |
| void | next (Queue &events) |
| Deliver what happened since the previous call. | |
| void | next (Queue &events, StampedMatQueue &frames) |
| void | next (Queue &events, StampedMatQueue &frames, ImuQueue &imus) |
 1.17.0